Ground classification: keeping the file's, or classifying it here
Three ways to get ground points out of a cloud, what the classifier actually does, and how to set it.
7 min read
The three choices
| Choice | What it does | When to use it |
|---|---|---|
| Keep the file's own classification, choosing which classes | Uses the points already marked with the ASPRS classes you tick, ground (2) for bare earth, or any class the file carries: road decks, building roofs, rail. Nothing is reclassified. | The cloud came classified and you trust whoever did it, including surfaces of things that are not ground |
| Classify the ground with Backsight | Ignores what the file says and works it out here, on settings you choose. | The cloud is unclassified, or you cannot see the settings behind its classification |
| Lowest point in each cell | Takes the lowest point in each grid cell. | A rough answer on a cloud with nothing else to go on |
Note
Whichever you choose, the source file is never altered. The surface simply records which method produced it.
How the classifier works
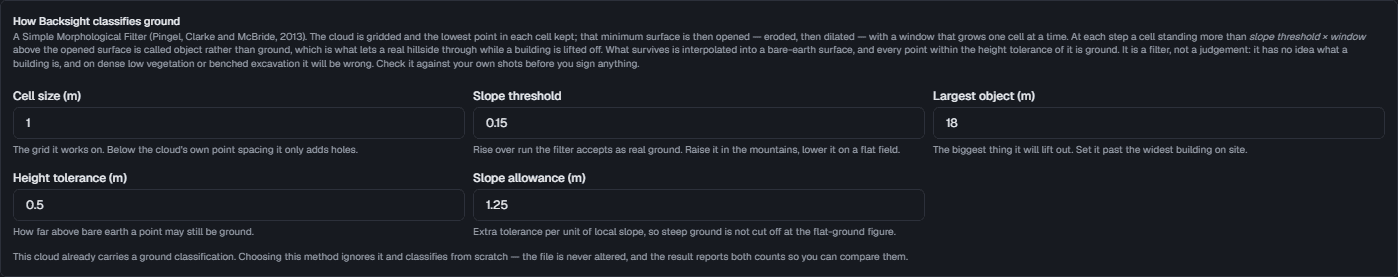
It is a Simple Morphological Filter, the published SMRF (Pingel, Clarke and McBride, 2013), with nothing added and nothing hidden.
In the order it runs:
- The cloud is gridded and the lowest point in each cell kept, giving a minimum surface.
- Cells with no point are filled from their nearest neighbours, and remembered, nothing is classified from a cell that never held a point.
- That surface is opened, eroded, then dilated, with a window that grows one cell at a time. At each step, a cell standing more than slope threshold × window above the opened surface is marked as object rather than ground.
- What survives is interpolated into a bare-earth surface.
- Every point within the height tolerance of that surface is ground, with an extra allowance for local slope.
A small window lifts cars and shrubs; a large one lifts buildings and tree stands. The slope threshold is what lets a real hillside through: on a 30 per cent slope, a 10 m window legitimately rises 3 m.
The settings
| Setting | Default | What to do with it |
|---|---|---|
| Cell size (m) | 1.0 | The grid it works on. Below the cloud's own point spacing it only adds holes. |
| Slope threshold | 0.15 | Rise over run it accepts as real ground. Raise it in the mountains, lower it on a flat field. |
| Largest object (m) | 18 | The biggest thing it will lift out. Set it past the widest building on site. |
| Height tolerance (m) | 0.5 | How far above bare earth a point may still be ground. Lower it to reject low shrubs. |
| Slope allowance (m) | 1.25 | Extra tolerance per unit of local slope, so steep ground is not judged at the flat-ground figure. |
Every one of these comes back with the result, along with how many points were called ground against how many the file itself had claimed, so a classified surface can be read and repeated.
What it gets wrong
It is a filter, not a judgement
It has no idea what a building is. On dense low vegetation, benched excavation or retaining walls it will get things wrong. Check a classified surface against your own shots, Surface check does exactly that, before you rely on it.
Read next
- Point clouds: reading, clipping and thinningUpload LAS, LAZ, E57, PLY or XYZ/PTS, see what is in it, and cut it down to the part you care about.
- Building a surfaceTriangulate points into ground you can contour, measure and stake from.
- Drone flights: from photos to productsUpload a flight, choose how it should be processed, and know what it costs before it starts.
Something here wrong or missing? Tell us and we will fix it.